Physicl raises $10 million to make the digital world real enough for robots
Physicl raised $10 million in seed funding led by Inovia Capital to launch Studio, providing 10,000 3D environments to train physical AI models for robots.
By Dillip Chowdary • Nov 07, 2026 • Source: TechCrunch
Physicl launched its core synthetic data platform, Studio, alongside fresh capital to supply physical artificial intelligence models and robotic systems with high-fidelity 3D simulation data. As detailed in TechCrunch's report, the venture is deploying a rendering pipeline originally developed over a decade for e-commerce to address the simulation-to-reality gap in robotics. The startup provides foundation model builders with synthetic training environments designed to reflect physical geometry, accurate materials, and real-world lighting conditions rather than relying purely on costly manual teleoperation.
This report examines the operational mechanics of Physicl, its commercial positioning in the physical artificial intelligence tooling market, and the technical architecture behind its simulation catalog. It is intended for robotic systems engineers, machine learning researchers building world models, and enterprise hardware teams evaluating synthetic training pipelines to overcome data collection bottlenecks. Readers will find concrete operational details on investor backing, edge-case generation workflows, early customer deployments, and the practical challenges of validating simulated physics against physical manipulation in dynamic environments.
The deal behind Physicl $10 million to make the digital world
The seed financing round totaled $10 million and was led by Inovia Capital, providing the startup with runway to expand its simulation infrastructure. Chief executive officer Alex de Vigan established Physicl after spending the prior decade leading nfinite, a venture that produced 3D models and digital renderings for consumer brands and online retailers. When transformer-based image generation models began encroaching on traditional e-commerce rendering services, de Vigan identified an unaddressed structural opening in artificial intelligence: the inability of standard generative models to understand, interact with, and manipulate physical space and tangible objects.
Rather than discarding the proprietary rendering infrastructure accumulated at nfinite, de Vigan repurposed the engineering stack to serve physical artificial intelligence and robotics developers. The transaction reflects an institutional shift among venture investors toward physical grounding layers, moving capital away from surface-level generative image creators and toward systems that enforce physical laws. Inovia Capital backed the round specifically to support Physicl in scaling its software assets and turning its historical 3D rendering pipeline into an ongoing data engine capable of serving foundation model builders who need reliable physical training environments.
Why Physicl $10 million to make the digital world raised
Robotics researchers working on physical artificial intelligence models have encountered steep diminishing returns when attempting to train manipulation systems purely on video feeds or manual human demonstrations. Gathering robot trajectories through remote teleoperation requires intensive labor, specialized operator hardware, and slow physical cycles that cannot scale to millions of hours of operational experience. Training models to handle diverse, small objects requires vast amounts of accurate visual and spatial data, leaving teams searching for synthetic alternatives that do not compromise on physical fidelity or require endless manual setup.
Digital simulations present a scalable training alternative, yet bridging the simulation-to-reality gap has remained an obstinate technical barrier across the robotics sector. When digital environments fail to accurately model real-world friction, lighting variations, material properties, and object geometry, policies trained inside simulators fail abruptly when deployed onto physical robot arms. De Vigan noted that his previous platform was engineered specifically to transform unstructured, incomplete, and heterogeneous real-world information into high-fidelity representations with correct geometry, materials, and physics, providing a pre-built technological foundation that justified raising institutional capital.
Advertisement
Tech Pulse Daily
Get tomorrow's pulse first
Join engineers who read Tech Pulse before stand-up. Free, weekday mornings.
What the Physicl $10 million to make the digital world money
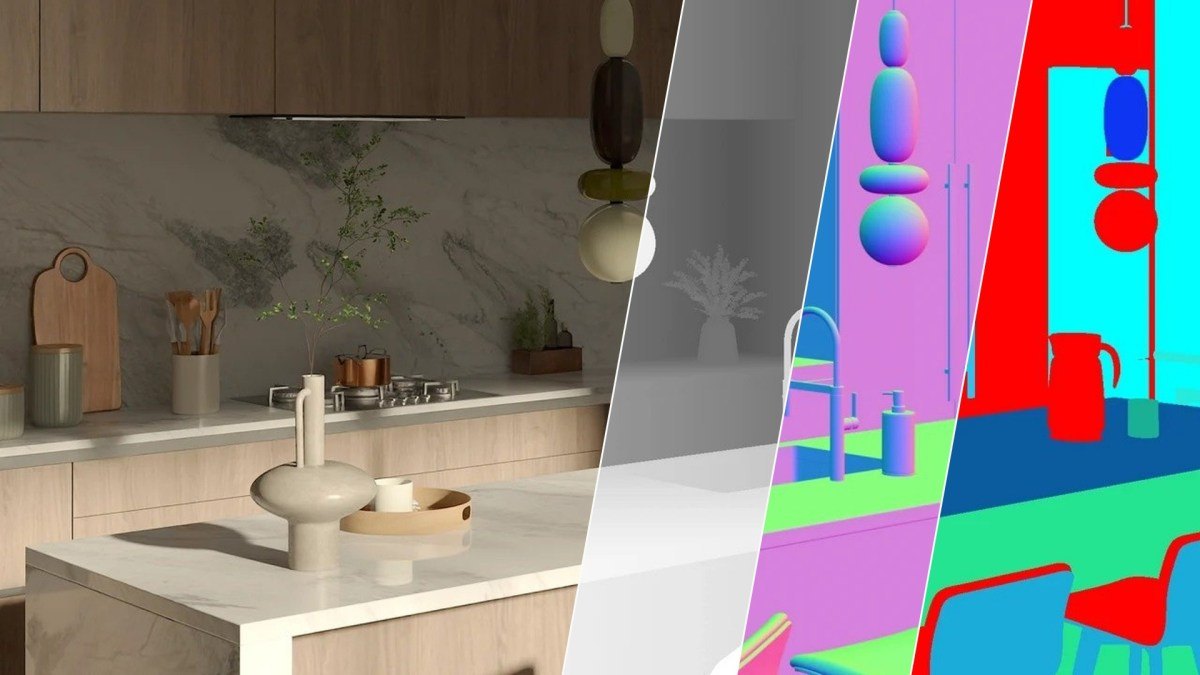
Capital from the seed round directly finances the release and operational expansion of Studio, Physicl's dedicated synthetic data generation platform. The initial release of Studio packages 10,000 distinct 3D environments alongside a library of 100,000 digital assets representing diverse everyday physical objects. The software enables machine learning teams to procedurally generate targeted synthetic scenarios to post-train robot models on difficult edge cases, such as identifying a transparent or occluded cup resting on a cluttered kitchen counter or locating items partially concealed by complex shadow patterns.
Beyond serving pre-rendered static assets, the startup is directing its funding toward continuous, automated data generation pipelines that function as an agentic workflow. De Vigan envisions enterprise clients supplying trillions of raw 2D images or millions of hours of lidar point-cloud captures directly into the platform, which will convert unstructured inputs into high-fidelity 3D representations. Roboticists can then use these spatial representations to generate billions of automated scene permutations, adjusting lighting, clutter density, object positions, and camera perspectives to test policy boundaries without manual human curation.
Competitive context for Physicl $10 million to make the digital world
Physicl enters an emerging but increasingly crowded category of infrastructure vendors competing to sell training data, evaluation environments, and tooling to foundation model teams. De Vigan acknowledged that the physical artificial intelligence market remains very young and blurry, with various competing startups collecting, labeling, or generating multimodal data to capture enterprise robotics accounts. Industry suppliers differ widely in their methodologies, with some providers relying on physical teleoperation farms and sensor fleets while others focus purely on algorithmic world simulation or neural radiance rendering to simulate environments.
Early customer validation has emerged through a commercial collaboration with SpAItial, an artificial intelligence world model developer whose founder and chief executive officer, Matthias Niessner, is also a robotics professor at the Technical University of Munich. SpAItial incorporated Physicl's high-fidelity synthetic data to train its Echo-3 model, which was released last week to generate interactive 3D simulations directly from flat 2D imagery. Niessner noted that competing with manual data curation requires high-fidelity synthetic assets that can be generated on the fly during active model training cycles.
Open questions on Physicl $10 million to make the digital world
A primary technical question confronting Physicl is whether synthetic 3D assets repurposed from e-commerce visual pipelines can achieve the rigorous mechanical accuracy demanded by precision industrial robotics. While commercial marketing renderings excel at photorealism, robot manipulation tasks require sub-millimeter geometric precision, accurate collision meshes, and nuanced contact physics across flexible, reflective, or deformable objects. Validating that synthetic scenes generated through Studio produce robust policies in the real world across diverse hardware platforms remains an ongoing engineering hurdle that model builders must verify empirically.
The second operational challenge centers on how smoothly Physicl can integrate into automated training loops that generate data dynamically without human intervention. Niessner highlighted the promise of closed-loop systems where an active model, such as Claude, monitors training progress, identifies specific data deficiencies, and triggers on-demand synthetic generation to fill the gap. Physicl must prove that its platform can reliably ingest unstructured lidar and imagery to deliver billions of valid training permutations at low computational latency and competitive operational cost before enterprise robotics programs adopt it at scale.
Developer Action Items
- ☐ Map where Physicl raises million make sits in your stack (SDK, API key, billing, data-processing addendum).
- ☐ Hold the $10 million figure to the primary report; do not brief a number that is not on the record.
- ☐ Hold non-urgent migrations until the integration or use-of-proceeds roadmap is public — day-one coverage is not a ship signal.
- ☐ If you are mid-contract or mid-POC, ask the vendor what changes for existing customers this quarter.
- ☐ Write the single decision this forces: stay, dual-source, or exit.
Physicl $10 million to make the digital world FAQ
How much funding did Physicl raise and who led the round?
Physicl secured $10 million in seed financing in a round led by Inovia Capital. The capital will fund infrastructure development and the rollout of its synthetic data generation platform.
What is Studio and what does it include?
Studio is Physicl's synthetic data tool designed to post-train robot models on complex edge cases. It features 10,000 distinct 3D environments and 100,000 digital assets representing diverse physical objects.
Who is Alex de Vigan and what was his background before Physicl?
Alex de Vigan is the founder and CEO of Physicl. Prior to founding the company, he spent a decade building nfinite, an e-commerce platform that created 3D models and digital renderings for retail brands.
How did SpAItial use Physicl's technology?
SpAItial, an AI world model builder led by Technical University of Munich professor Matthias Niessner, partnered with Physicl to train its Echo-3 model, which creates 3D simulations directly from 2D images.
Sources

Author
Dillip Chowdary
Writes Tech Bytes coverage of AI, engineering, and the tools that actually ship. Editor of Tech Pulse Daily.
Related on Tech Bytes
Advertisement